

This talk presents scalable cooperative control and planning for future mobility systems. It covers detour planning for ride-pooling that improves vehicle utilization, sustainability, and service quality; decentralized planning for dual-task urban air mobility, where drone fleets combine parcel delivery with traffic monitoring; and co-design of connected and automated vehicle routing with adaptive signal control to improve network-wide efficiency in mixed traffic. These approaches use learning and control methods with rigorous theoretical guarantees, enabling decentralized decisions at low communication and computational cost.
ABOUT THE LECTURER
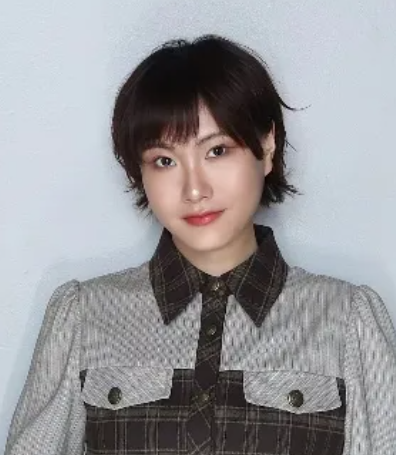
Dr. Pengbo Zhu is a Postdoctoral Research Associate in the School of Civil and Environmental Engineering at Cornell University, working with Prof. Andreas A. Malikopoulos. She holds a Ph.D. from EPFL and develops scalable, theoretically grounded methods for large-scale multi-agent systems, spanning mobility-on-demand, connected and automated vehicles, and urban air mobility. She received the SNSF Postdoc.Mobility Fellowship and the hEART 2025 Best Paper Award, and was selected for the 2026 CEE Rising Stars cohort.