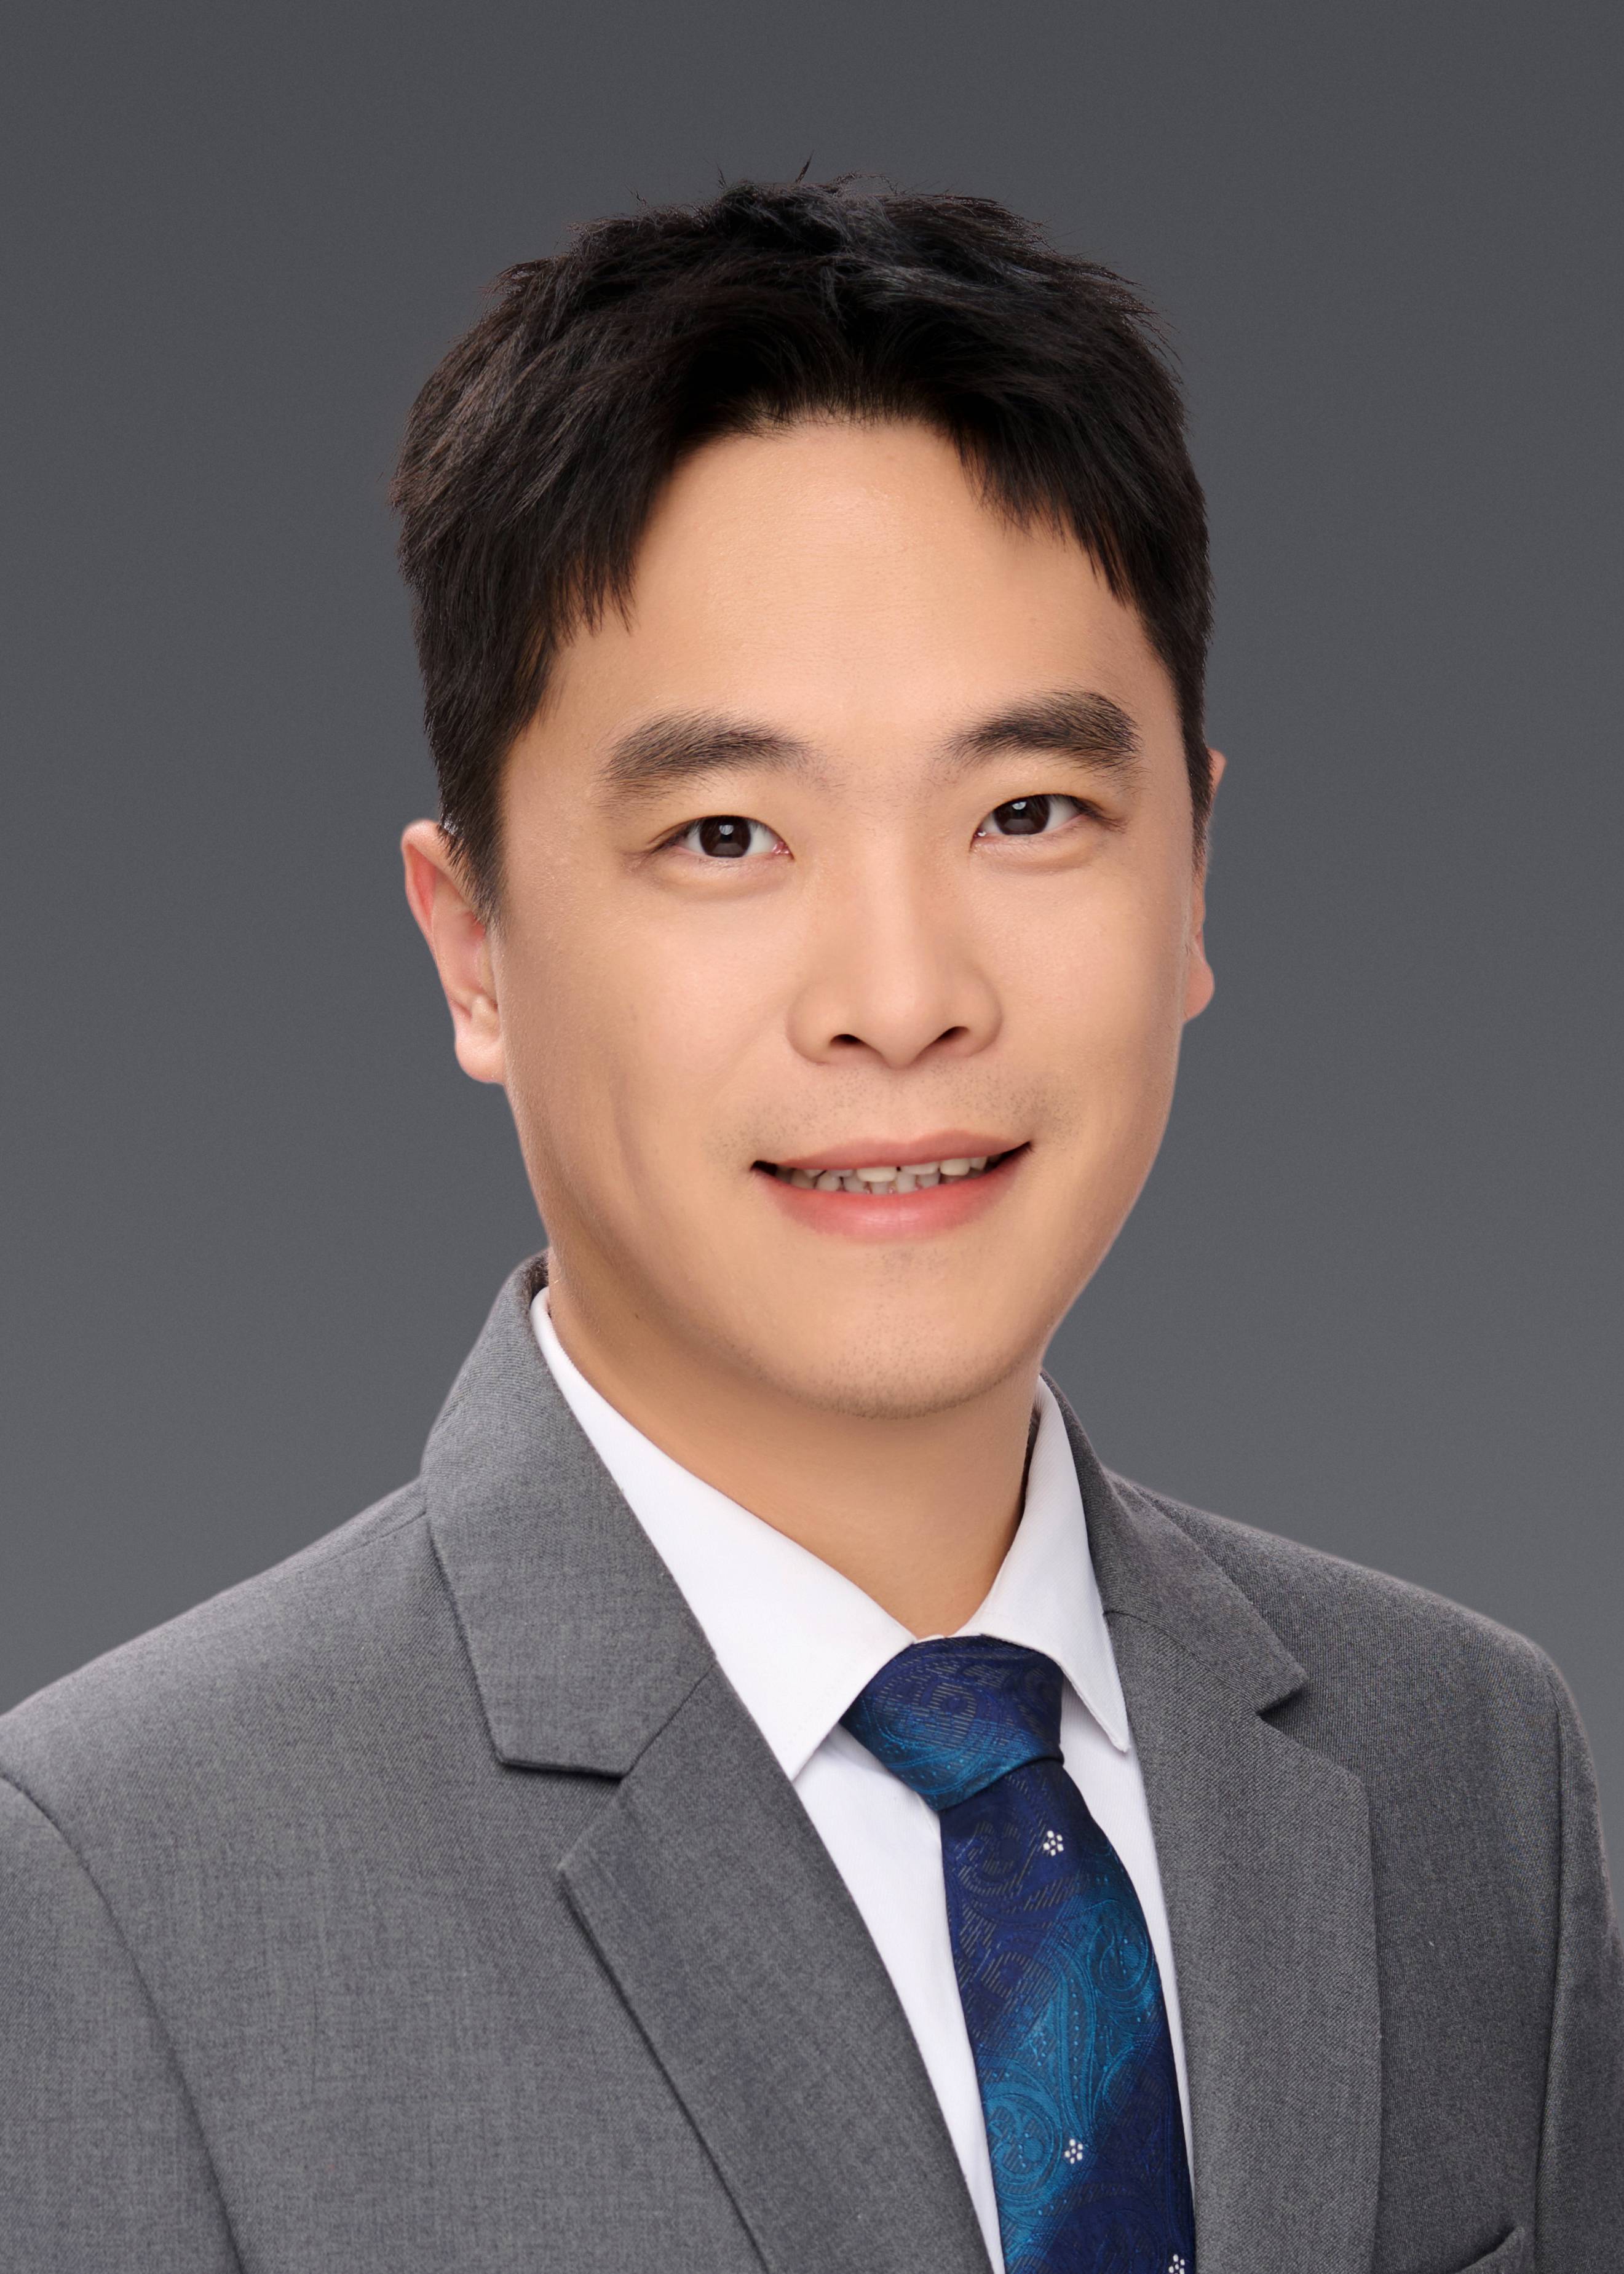
2021年博士毕业于东南大学禁漫天堂官网,期间前往美国威斯康星大学麦迪逊分校联培。
2026.09-至今,东南大学,禁漫天堂官网,副研究员,博导
2026.01-2026.09,东南大学,禁漫天堂官网,副研究员,硕导
2021.09-2026.01,东南大学,禁漫天堂官网,至善博士后(合作导师:冉斌教授)
智能网联车辆智能优化控制与决策
1. 国家自然科学基金面上项目:基于势场理论的非结构化道路驾驶可行域建模与交通协同控制方法,2026-2029,主持
2. 国家自然科学基金青年项目:基于安全势场建模的快速路交织区风险预警方法,2023-2025,主持
3. 科技部科技创新2030—重大项目子课题:微观车辆个体行为与宏观系统状态映射机制,2022-2025,主持
4. 中国博士后科学基金面上项目:道路实时风险地图构建与交通安全保障策略研究,2021-2022,主持
5. 教育部产学合作项目:基于人因与工效学的智能网联交通安全监管体系教学资源开发,2023-2026,主持
6. 江苏省卓越博士后计划项目:基于安全势场的混合交通流运动态势模型研究,2022-2023,主持
7. 智能警务四川省重点实验室开放课题面上项目:交织区驾驶风险预警方法与交通安全保障策略研究,2023-2025,主持
8. 江宁区现代物流发展规划技术支持服务采购项目,2024-2025,主持
9. 自动驾驶开放道路复杂度分级服务,2024-2025,主持
10. 鄂尔多斯市科技“突围”工程“揭榜挂帅” 重大项目课题:新能源自动驾驶重卡编队系统验证,2025-2028,参与
[1]一种智能网联车辆最优速度控制和车队分离方法,发明专利(授权),李林恒(1/5)CN117762132B,2026.06.02
[2]一种基于安全势场的道路风险地图生成方法及系统,发明专利(授权),李林恒(1/5),CN115420274B,2025.03.18
[3]基于强化学习考虑硬路肩开放的高速公路单匝道管控方法,发明专利(授权),李林恒(2/5),CN118411834B,2025.01.21
[4]适用于混合交通流的动态协作合流控制方法及系统,发明专利(授权),李林恒(2/4)CN117409564B,2025.11.14
[5]一种面向混合交通环境的交通流微观模型优化方法,发明专利(授权),李林恒(2/6)CN115099002B,2024.12.31
[6]一种高速公路断面交通流量预测方法、装置及存储介质,发明专利(授权),李林恒(2/5)CN117636624B,2024.12.31
[7]一种面向高速公路的自动驾驶专用道及设置方法,发明专利(授权),李林恒(3/7),CN116386368B,2024.03.26
[8]一种基于安全风险场的宏观区域车辆预警方法及系统,发明专利(授权),李林恒(3/3),CN118116236B,2024.12.31
[9]基于Transformer的高速公路交通状态估计方法,发明专利(授权),李林恒(2/5),CN117576897B,2024.12.03
[10]一种智能网联车队形成控制方法、计算装置、存储介质和车辆,发明专利(授权),李林恒(3/4),CN118298615B,2025.01.21
[11]一种面向轨迹数据的车辆异常数据筛选方法,发明专利(授权),李林恒(3/7),CN116469251B,2024.11.29
[12]一种智能网联车辆队列的关键控制节点识别方法、装置及存储介质,发明专利(授权),李林恒(3/5),CN117576905B,2024.11.26
[13]一种服务于低碳道路交通规划的道路网碳排放估算方法,发明专利(授权),李林恒(3/4),CN112613652B,2024.07.12
[14] 一种基于评价指标改进FCM的高速路交通参数估计方法,发明专利(授权),李林恒(7/8)CN117670111B,2026.06.30
[15] 一种交通合流控制方法及系统,发明专利(授权),李林恒(8/8),CN119942780B,2025.11.04
2026年
[1]Li L, Nan T, Gan J, et al. Ethical Decision-Making in Autonomous Vehicles: A Reinforcement Learning Approach for Fair Risk Management[J]. Transportation Research Part C: Emerging Technologies, 2026, 190: 105761.(JCR一区,交通运输领域顶刊)
[2]Liu C, Hu H, Ma T,Zhang Y, Jia M,Li L*, et al. Trajectory planning for traffic safety with dynamic ethical risk adjustment[J]. Accident Analysis & Prevention, 2026, 229: 108425.(JCR一区,安全领域顶刊,一作为指导的本科生)
[3]Gan J, Bi H, Wu Y,Li L*, et al. Prediction-enhanced intelligent driver model: Integrating transformer-based foresight into car-following dynamics[J]. Expert Systems with Applications, 2026, 306: 130947.(JCR一区,人工智能领域顶刊)
[4]Wang Z, Li L, Qu X, et al. Detecting Abnormal Vehicle Behavior with a Diffusion-Transformer Generation Framework[J]. IEEE Internet of Things Journal, 2026.(JCR一区,物联网领域顶刊)
[5]Wang Z, Wang C, Li L, et al. Vehicle group risk modeling based on risk propagation mechanism[J]. Accident Analysis & Prevention, 2026, 237: 108707.(JCR一区,安全领域顶刊)
[6]Huang X, Li L, Wang Z, et al. V2X-Based Cooperative On-Ramp Merging Control Strategy with In-Lane and Cross-Lane Platoons[J]. Journal of Transportation Engineering, Part A: Systems, 2026, 152(3): 04025145.(JCR三区)
[7]Gan J, Zhang D, Bai W, Li L,et al. Traffic state reconstruction in heterogeneous traffic flow from multi-source partial observations: A self-supervised and physics-informed framework[J]. Physica A: Statistical Mechanics and its Applications, 2026: 131785.(JCR二区)
[8]Wang C, Wang W, Zhao Y, Li L,et al. Empowering cooperative control for vehicle groups in merging areas: A trajectory-data-driven critical vehicle identification approach[J]. Transportation Research Part C: Emerging Technologies, 2026, 188: 105693.(JCR一区,交通运输领域顶刊)
2025年
[1]Ma, H, Qian, C,Li, L*, et al. Risk quantification based Adaptive Cruise control and its application in approaching behavior at signalized intersections [J]. Accident Analysis & Prevention, 2025, 212: 107939.(JCR一区,安全领域顶刊)
[2]CuiC, AnB , Li L*, et al. A unified risk metric for freeway vehicles based on the spatio-temporal overlap probability of predicted positions[J]. Accident Analysis & Prevention, 2025.(JCR一区,安全领域顶刊)
[3]Wang C, Zhao Y, Li L*, et al. Enhancing Vehicle Platoons in Connected and Automated Environments With an Improved Spectral Clustering-Based Pinning Control Strategy[J]. IEEE Transactions on Vehicular Technology, 2025.(JCR一区,车辆工程领域顶刊)
[4]Zhou, Z, Wang, C, Ma, H, An, B, Li, L, et al. Mitigating traffic oscillations through connected and automated vehicle control: a platoon-level cooperative adaptive cruise control strategy with optimal sub-platoon formation[J].Applied Mathematical Modelling, 2025,116681.(JCR一区,数学建模领域顶刊)
[5]Ma, H , Qian, C , Li, L, et al. A novel 2D motion planning method for vehicles considering the impact of lane configurations[J]. Transportation Research Part C: Emerging Technologies,2025, 177, 105186.(JCR一区,交通运输领域顶刊)
2024年
[1]Li L, QianC,Gan J, et al. DCoMA: A dynamic coordinative merging assistant strategy for on-ramp vehicles with mixed traffic conditions [J]. Transportation Research Part C: Emerging Technologies, 2024, 165: 104700. (JCR一区,交通运输领域顶刊)
[2]Li L, Gan J, Cui C, et al. Potential field-based modeling and stability analysis of heterogeneous traffic flow[J]. Applied Mathematical Modelling, 2024, 125: 485-508.(JCR一区,数学建模领域顶刊)
[1]Li L, An B, Zhang D, et al. Vehicular speed prediction method for highway scenarios based on spatio-temporal graph convolutional networks and potential field theory[J]. IEEE Internet of Things Journal, 2024. 12(3):3330-3349.(JCR一区,物联网领域顶刊)
[3]Li L, Li S, Gan J, et al. Revealing the impact of stochastic driving characteristics on car-following behavior with locally collected vehicle trajectory data[J]. Transportmetrica B: transport dynamics, 2024, 12(1): 2299993.(JCR三区)
[4]Li L, Wang C, Gan J, et al. Optimizing platoon safety through key node selection in pinning control strategy[J]. Physica A: Statistical Mechanics and its Applications, 2024, 643: 129830.(JCR二区)
[5]Li L, An B, Wang Z, et al. Stability analysis and numerical simulation of a car-following model considering safety potential field and V2X communication: A focus on influence weight of multiple vehicles[J]. Physica A: Statistical Mechanics and its Applications, 2024, 640: 129706.(JCR二区)
[2]Ma H, Qian C, Li L*, et al. Progressive virtual risk-based vehicle trajectory optimization in mixed traffic flow[J]. Transportation Research Part C: Emerging Technologies, 2024, 165: 104701.(JCR一区,交通运输领域顶刊)
[3]Gan J, Yang Q, Zhang D, Li L*, et al. A Novel Voronoi-Based Spatio-Temporal Graph Convolutional Network for Traffic Crash Prediction Considering Geographical Spatial Distributions[J]. IEEE Transactions on Intelligent Transportation Systems, 2024,25(12):21723-21736.(JCR一区,智能交通领域顶刊)
[6]Gan R, An B, Li L*, et al. A Freeway Traffic Flow Prediction Model Based on a Generalized Dynamic Spatio-Temporal Graph Convolutional Network[J]. IEEE Transactions on Intelligent Transportation Systems, 2024,25(10):13682-13693.(JCR一区,智能交通领域顶刊)
[7]Gan J, Ma H, Li L*, et al. Linear Stability of Heterogeneous Traffic Flow Incorporating V2X Communication and Intra-Platoon Spatial Distribution[J]. IEEE Internet of Things Journal, 2024,11(24):41033-41048.(JCR一区,物联网领域顶刊)
[8]Cui C, An B, Li L*, et al. A freeway vehicle early warning method based on risk map: enhancing traffic safety through global perspective characterization of driving risk[J]. Accident Analysis & Prevention, 2024, 203: 107611.(JCR一区,安全领域顶刊)
[9]Wang C, Zhao Y, Li L*, et al. A Traffic Flow Data Restoration Method Based on an Auxiliary Discrimination Mechanism-Oriented GAN Model[J]. IEEE Internet of Things Journal, 2024,11(12):22742-22753.(JCR一区,物联网领域顶刊)
[10]王灿,赵妍,李林恒*,等.智能网联环境下基于谱聚类的车辆群体牵制控制策略[J].中国公路学报, 2024, 37(11):235-248.(交通工程领域中文TOP期刊)
[11]Zhou Z, Li L*, Qu X, et al. A self-adaptive IDM car-following strategy considering asymptotic stability and damping characteristics[J]. Physica A: Statistical Mechanics and its Applications, 2024, 637: 129539.(JCR二区)
[12]Zhou Z, Li L*, Qu X, et al. PACC: A platoon-based adaptive cruise control strategy based on leader-following information topology to mitigate traffic oscillations under CAV environment[J]. Physica A: Statistical Mechanics and its Applications, 2024, 654: 130117.(JCR二区)
[13]Wu R, Li L, Shi H, et al. Integrated driving risk surrogate model and car-following behavior for freeway risk assessment[J]. Accident Analysis & Prevention, 2024, 201: 107571.(JCR一区,安全领域顶刊)
2023年以前
[1]Ma H, Li L, An B, et al. Mass‐based omni‐directional risk indicator (MORI) for multi‐participant traffic[J]. IET Intelligent Transport Systems, 2023, 17(11): 2251-2267.(JCR三区)
[2]Li L, Gan J, JiX, et al. Dynamic Driving Risk Potential Field Model under the Connected and Automated Vehicles Environment and Its Application in Car-following Modeling [J]. IEEE Transaction on Intelligent Transportation Systems, 2022, 23(1):122-141.(JCR一区,智能交通领域顶刊,ESI高被引)
[3]Li L, Wang C, Zhang Y, et al. Microscopic state evolution model of mixed traffic flow based on potential field theory[J]. Physica A: Statistical Mechanics and its Applications, 2022, 607: 128185.(JCR二区)
[4]Li L, Gan J, Qu X, et al. A dynamic control method for cavs platoon based on the MPC framework and safety potential field model[J]. KSCE Journal of Civil Engineering, 2021, 25(5): 1874-1886.(JCR三区)
[5]李林恒,甘婧,曲栩,等.智能网联环境下基于安全势场理论的车辆换道模型[J].中国公路学报, 2021, 34(6):12.(交通工程领域中文TOP期刊)
[6]Li L, Gan J , Yi Z ,et al.Risk perception and the warning strategy based on safety potential field theory[J].Accident Analysis & Prevention, 2020, 148.(JCR一区,安全领域顶刊)
[7]李林恒,甘婧,曲栩,等.智能网联环境下基于安全势场理论的车辆跟驰模型[J].中国公路学报, 2019(12):12.(交通工程领域中文TOP期刊)
荣誉奖励:
1. 东南大学第41个教师节表彰,2025
2. 东南大学禁漫天堂官网竞赛指导贡献奖,2024
3. 中国精品科技期刊顶尖学术论文领跑者F5000,2024
4. 中国知网《学术精要数据库》三高(高PCSI、高被引、高下载)论文,2023
5. 《中国公路学报》优秀论文优秀论文提名奖,2023
6. International Symposium on Accident Analysis & Prevention最佳论文奖,2021
7. 《中国公路学报》优秀论文三等奖,2021
8. 江苏省卓越博士后,2021
竞赛指导获奖:
1. 第二十届全国大学生交通运输科技大赛一等奖,2025
2. 第十九届全国大学生交通运输科技大赛一等奖,2024
3. 第十届江苏大学生交通科技大赛二等奖(获评优秀指导老师),2025
4. 第九届江苏大学生交通科技大赛一等奖(获评优秀指导老师),2024
5. 第29届智能交通世界大会创新大赛三等奖,2023
1.WTC交通工程学部交通能源环境科学智能驾驶能源环境技术委员会主席
2.WTC交叉学科学部车联网与自动驾驶学科CAV与道路交通技术委员会青年委员
3.WTC交通工程学部车路云一体化交通学科智能网联道路技术委员会青年委员
4.WTC交叉学科学部数据与信息学科数据融合感知与特征提取技术委员会青年委员
热忱欢迎对学术科研有浓厚兴趣的同学联系。无专业背景要求,包括但不限于交通、信息、计算机、数学、自动控制等,但你必须勤奋踏实。能够提供较好的国内外学术交流与联培访学机会。欢迎本科生积极联系参与SRTP项目和交科赛等各类竞赛。
 地址:江苏省南京市江宁区东南大学路2号禁漫天堂官网
邮编:211189
 邮箱:seutc_official@126.com
© 2026 School of Transportation, Southeast University. All Rights Preserved